Kinects360 on table
The idea is set two fixed Kinects360 on a table as shown in figure 1. It can be constructed the entire scene of all objects placed on the table by applying point cloud processing, as shown in figure 2.
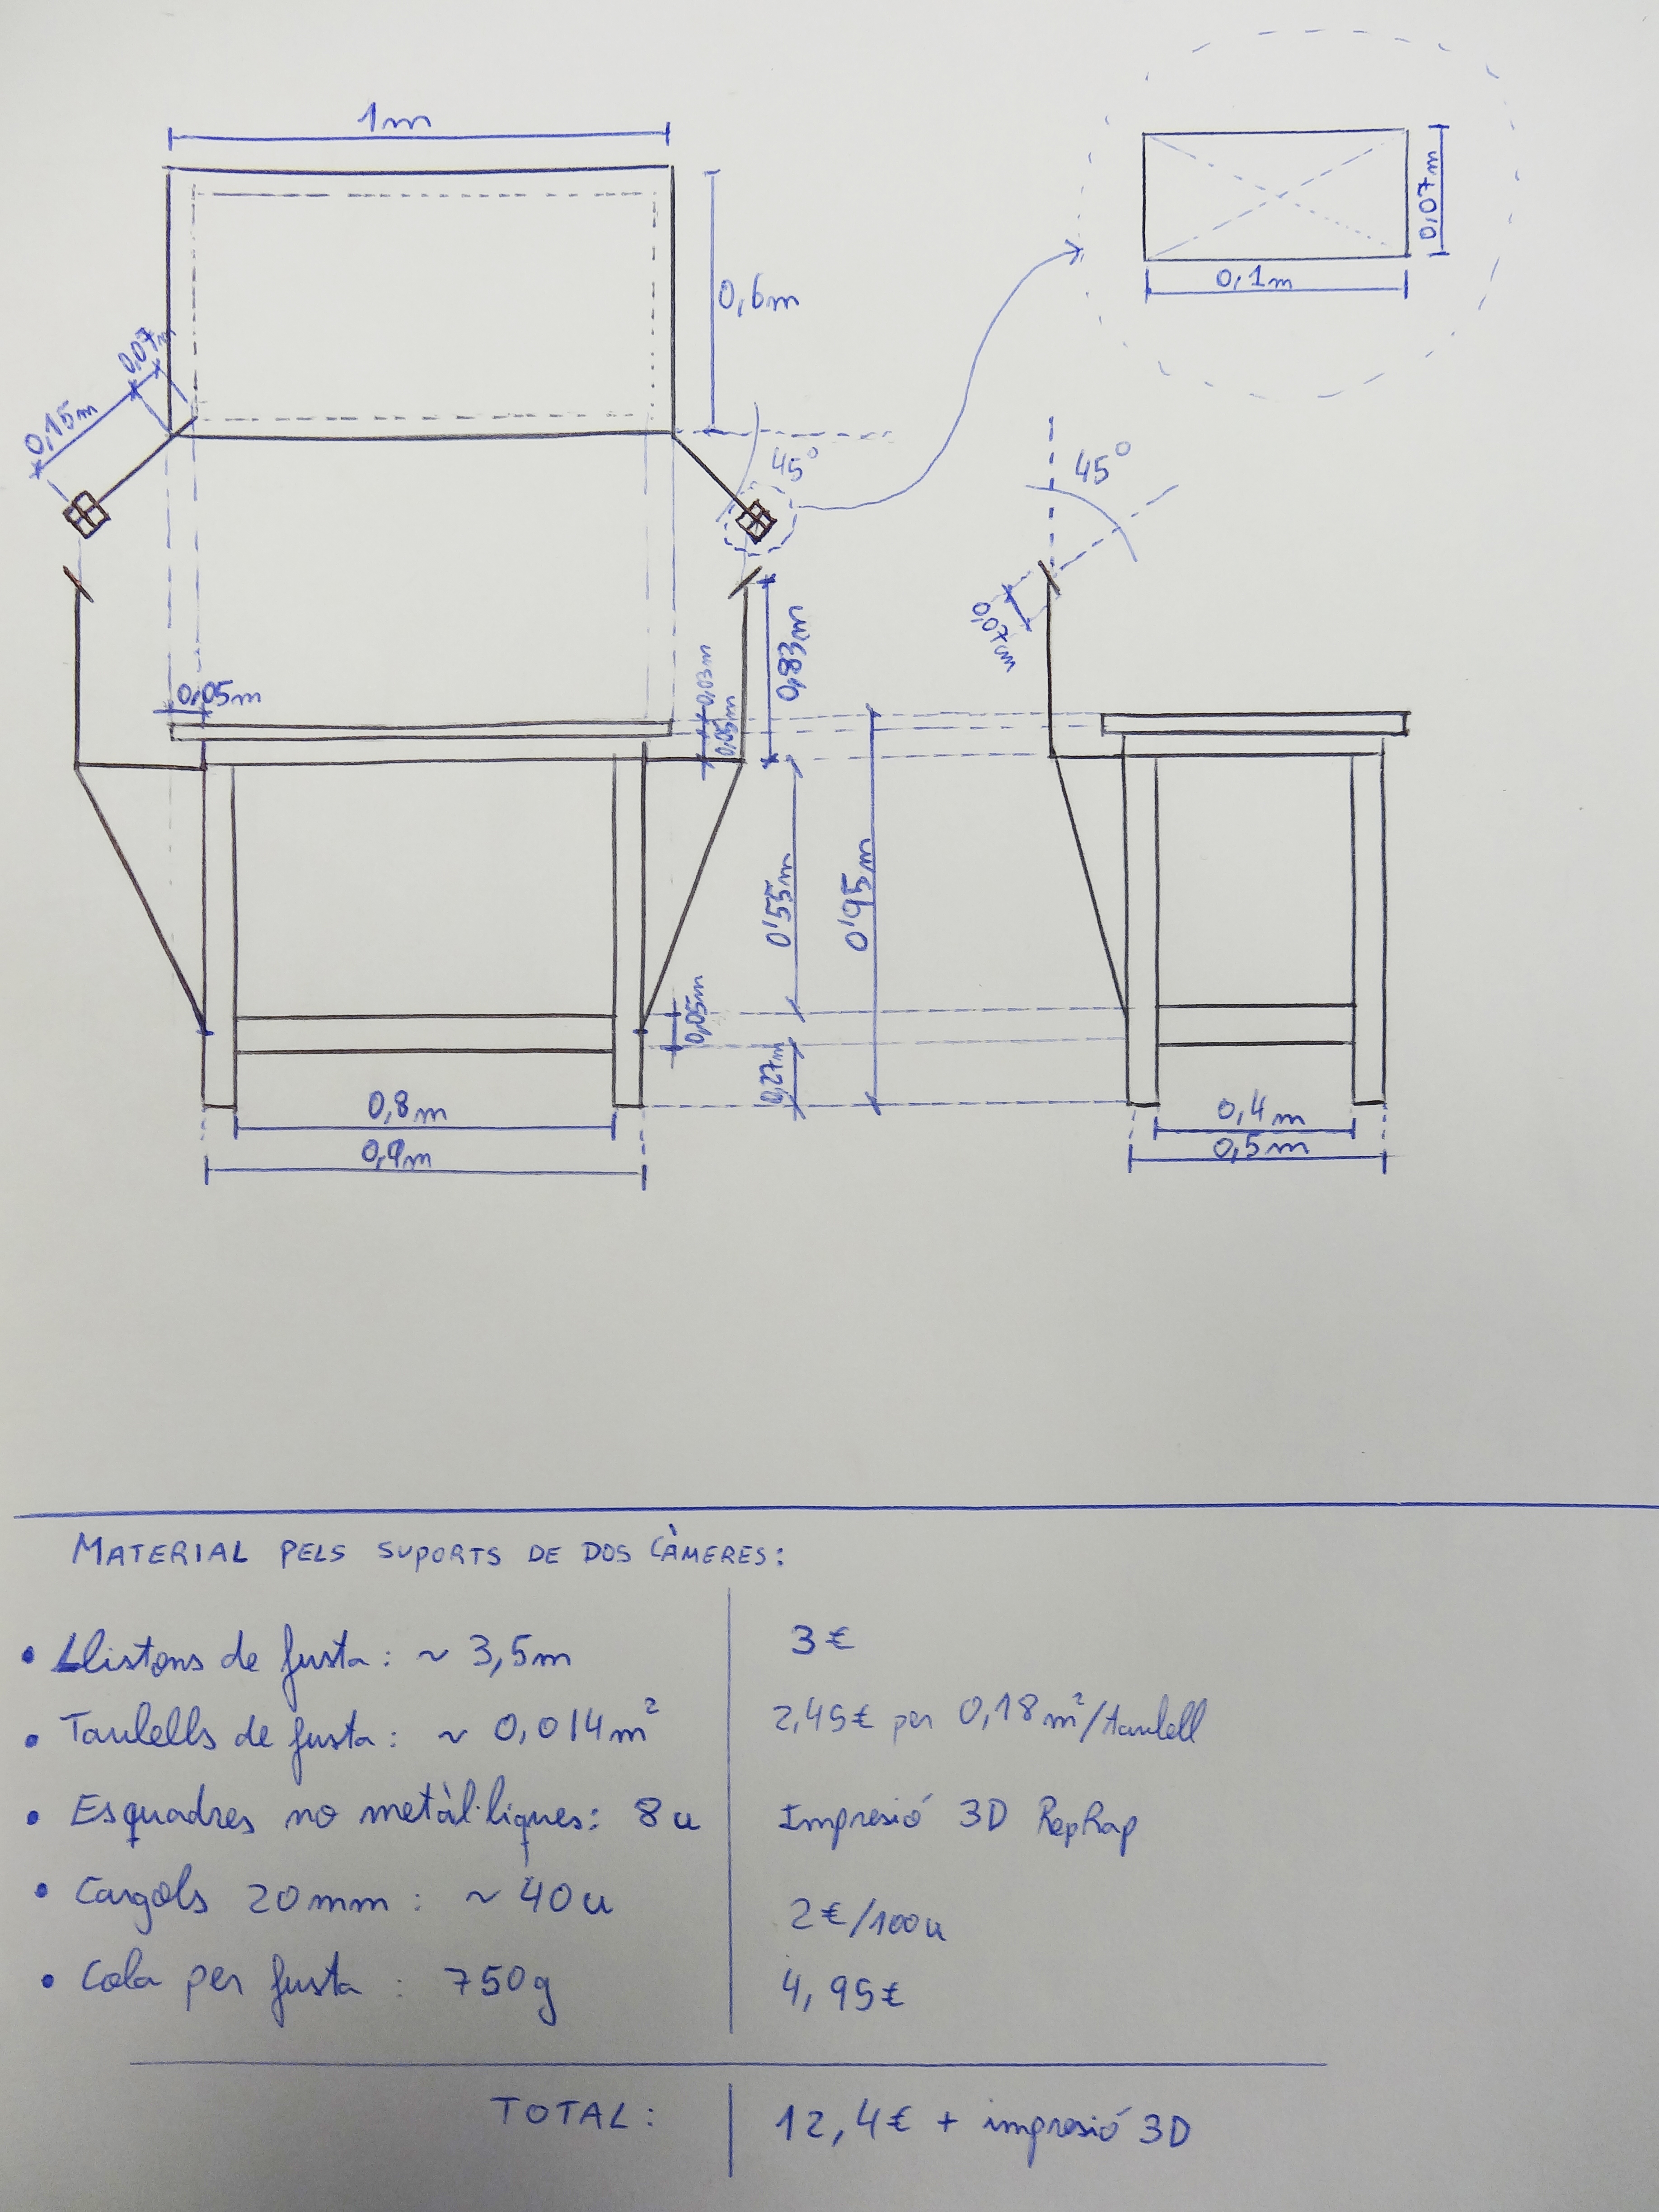 Figure 1. Schemme Kinects. |
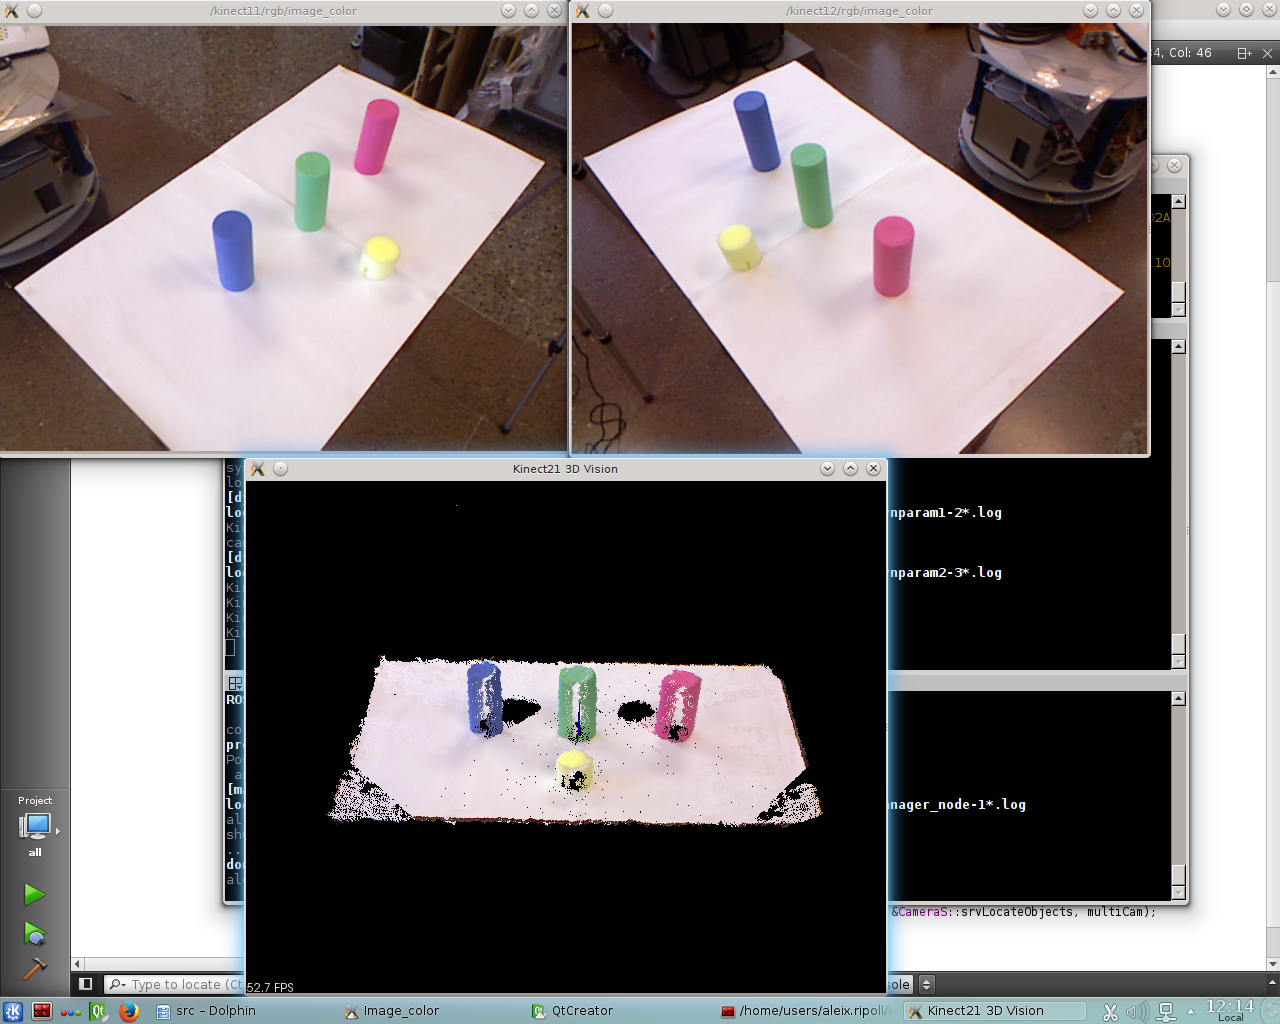 Figure 2. View of two Kinect360 (both point clouds are merged). |
Other possibilities can be placing a single camera at the middle of the table and placing two of them. The results of bot possibilities are shown below.
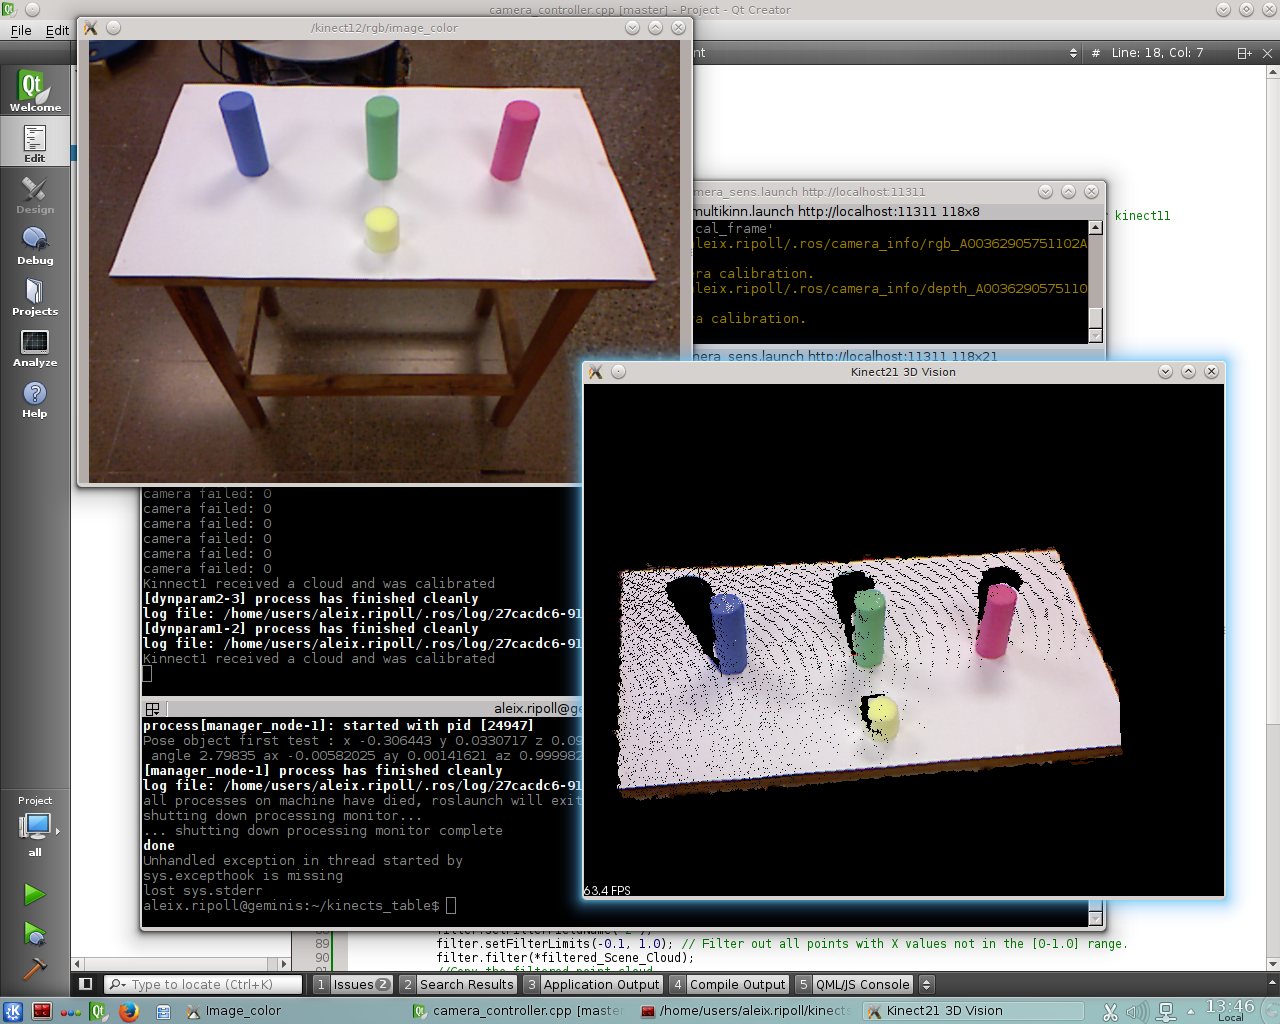 Figure 3. View of single Kinect360. |
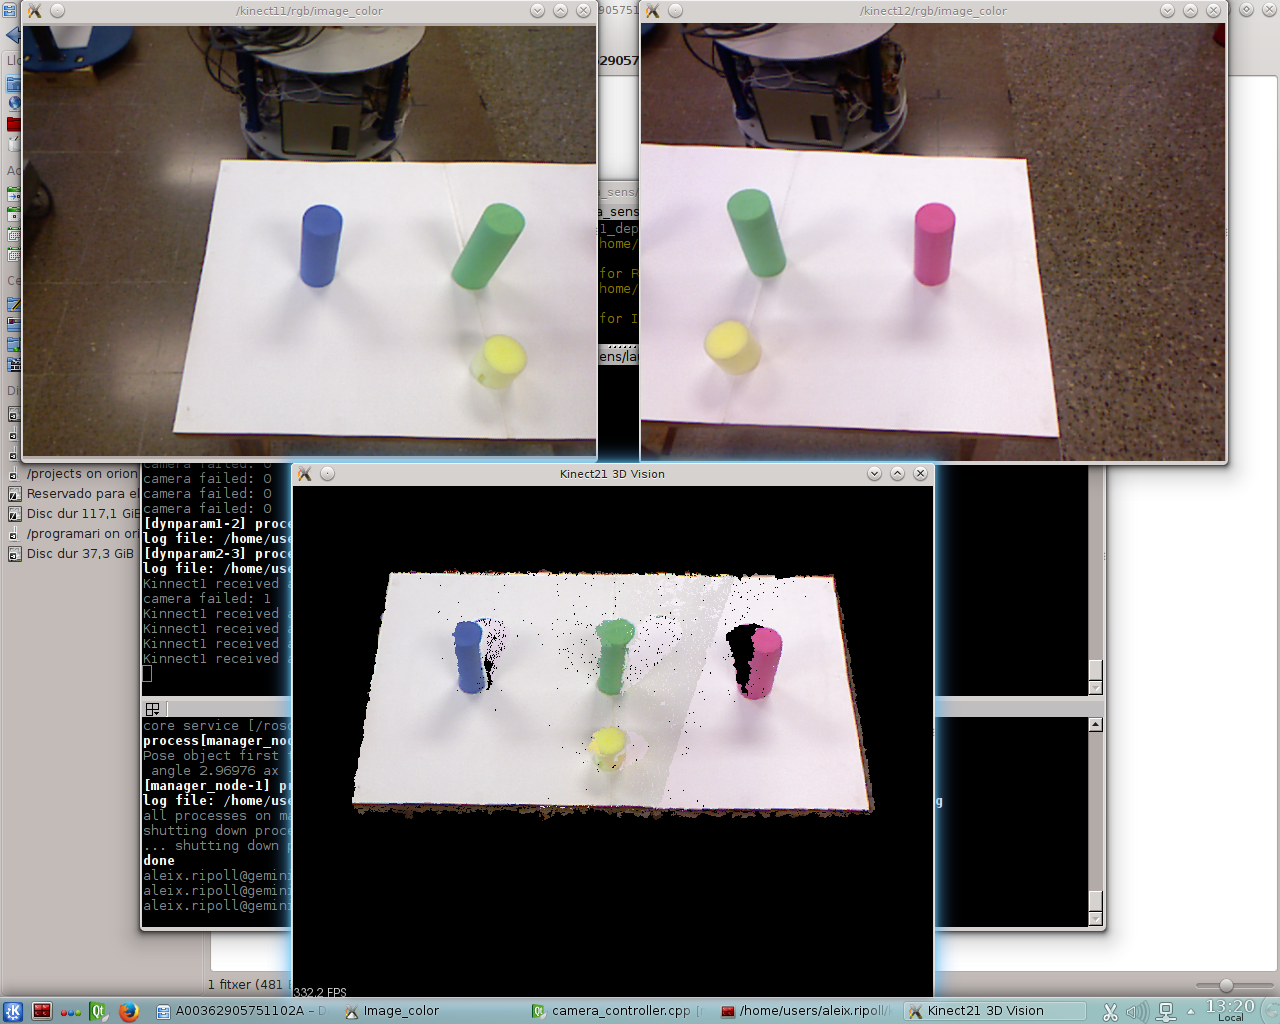 Figure 4. View of two Kinect360 (both point clouds are merged). |